
 Worksheets
S2 Adv. Robotics EOC
Total questions: 20
Worksheet time: 40mins
True or False: A user can change the behavior of a robot by changing the commands.
True
False
How can you make the VR Robot move in reverse on the [Drive for] block?
Changing the "forward" parameter to "reverse".
Changing millimeters (mm) to Inches.
Increasing the numeric value.
Moving the block to the bottom of the project.
Which of the following blocks is used to repeat the blocks inside of it for a set number of times?
[Forever] block
[Repeat] block
[Wait until] block
[Break] block
The [Wait until] block is a Control block that accepts Boolean values.
True
False

What will happen when the (Distance from) block reports that it is less than 50 millimeters (mm) from an object?
The VR Robot will turn right for 90 degrees.
The VR Robot will stop.
The VR Robot will drive forward.
The project will restart.
Which statement is TRUE for waiting blocks?
They wait for the user to select the "Step" button.
They wait until the VR Robot has enough power to complete the task.
They allow the rest of the stack to continue even if that block's behavior has not been completed.
They pause the stack until that block's behavior has been completed.
What do sensors do?
Allow the robot to sense and react to changes in the environment.
Tell you if it's hungry.
Tell the temperature in the room.
Be able to tell when you are upset.
What does the Gyro sensor detect?
Color
Touch
Distance
Rotation

What does this code do?
Run the robot straight until it touches something, make it turn left then go forward. This code is run 3 times.
Run the robot straight until it touches something, make it turn right then go forward. This code is run 3 times.
Run the robot straight until it touches something, make it turn right then go backwards. This code is run 3 times.
Run the robot straight until it touches something, make it turn right then go forward. This code is run 1 time.

How can the following example be simplified by using a [Repeat] block?
By placing the [Drive for] and [Turn for] blocks in a [Repeat] block that repeats four times.
By placing the [Drive for] block in a [Repeat] block that repeats four times.
By placing the [Turn for] block in a [Repeat] block that repeats four times.
By changing all of the parameters of the [Drive for] blocks to 400 millimeters (mm) instead of 200 millimeters (mm).
Which of the following describes why a [Repeat] block would be used in a project?
To repeat certain blocks forever.
To save space and time for blocks that repeat more than once in a project.
To only run a stack of blocks one time.
To run an attached stack of blocks when the project is started.

What is this part?
pulley
wheel hub
plate
gear
A ________ is any device that detects & responds to some input from the physical environment.
motor
sensor
red hot poker
program
________ is a spinning force directed in a circle, most often rotating an object.
Friction
Center of gravity
Torque
Load


What is the GEAR RATIO for this gear train?
24:1
3:1
6:2
1:12
If you wanted to pick up cubes with the VexIQ claw-bots arm, which of the following mechanical advantages would be best to have?
Torque
Speed
Dimension
Motion
What is an Input?
Information that is received
Controlled action that is carried out
a sensor
Electrical systems device
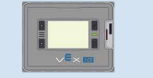
What is this part?
robot brain
controllor
sensor
motor

